Trust and Safety in Autonomous Vehicles: Evaluating Contextual Visualizations for Highlighting, Prediction, and Anchoring
Abstract
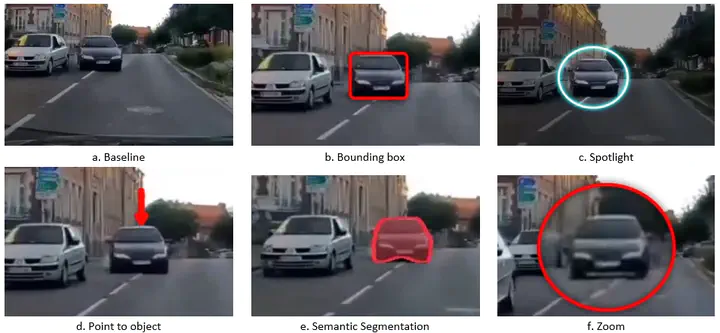
Three online studies evaluate AR highlighting, trajectory prediction, and spatial anchoring in simulated autonomous-vehicle scenarios. The findings show that appropriate highlights depend on the scenario, single-path predictions are clearer than multi-goal visualizations, and world-fixed time-to-contact information improves trust, perceived safety, and object detectability.
Type
Publication
ICAT-EGVE 2025: International Conference on Artificial Reality and Telexistence and Eurographics Symposium on Virtual Environments, The Eurographics Association
Thi Thanh Hoa Tran
PhD Student in Virtual Reality
Etienne Peillard
Associate Professor
My research focuses on perception and embodied interaction in Virtual and Augmented Reality, including augmented affordances, body perception, and human-system cooperation in immersive environments.
James Walsh
Enterprise Fellow
Guillaume Moreau
Dean for Research and Innovation of IMT Atlantique